Introduction#
ctis is a Python library for simulating and inverting observations from
computed tomography imaging spectrographs
(CTISs), particularly those designed to observe the Sun in the extreme ultraviolet.
A slit spectrograph records the spectrum of one strip of the scene at a time. A CTIS has no slit: each of its channels disperses the entire field of view onto a sensor, so position and wavelength are mixed together along the dispersion direction of every image. Observing the same scene with several dispersion directions at once turns the recovery of the spectral cube into a limited-angle tomography problem, which is how instruments such as the Multi-Order Solar EUV Spectrograph (MOSES) [Fox et al., 2010] and the EUV Snapshot Imaging Spectrograph (ESIS) [Parker et al., 2022] measure the intensity, Doppler shift, and width of a spectral line over a two-dimensional field of view in a single exposure.
ctis provides models of these instruments, which map a spectral scene to the images on
the sensor, and inversion algorithms, which reconstruct the scene from those images.
It is built on named_arrays, so every scene and image carries named axes and physical
units, and an instrument model can be built from an optika model of the optical system.
Installation#
This package is published on PyPI and can be installed using pip
pip install ctis
ctis requires Python 3.12 or newer.
To upgrade an existing installation,
along with the versions of named_arrays and numpy that it needs, use
pip install --upgrade ctis
Features#
IdealInstrument, a CTIS defined by its effective area, plate scale, and the magnitude and angle of the dispersion of each channel, with photon shot noise and Gaussian read noise.OptikaInstrument, a CTIS whose forward model is anoptikalinear system, which supplies the distortion, effective area, vignetting, and sensor response.A forward model,
image(), which maps the spectral radiance of a scene to the electrons measured by the sensor, optionally with the uncertainty of each pixel, and its transpose,backproject().MartInverter, an implementation of the multiplicative algebraic reconstruction technique (MART) [Gordon et al., 1970], which iterates until the mean \(\chi^2\) of the predicted images stops improving.Merit functionsfor judging an inversion: the mean \(\chi^2\), and the correlation between the predicted images and the residuals.gaussians(), a synthetic test scene of Gaussian blobs with different Doppler shifts, andplot_moments(), which compares the radiance, Doppler shift, and line width of a reconstruction against the true scene.
Key concepts#
Scenes and images are functions of named coordinates.
A scene is a FunctionArray of spectral radiance evaluated on
coordinates_scene,
a grid of wavelengths and positions on the sky,
and the images are a FunctionArray of electrons evaluated on
coordinates_sensor,
the vertices of the pixels on the sensor.
The channels are the elements of a named axis.
The channels of a CTIS lie along the axis named by
axis_channel,
and every parameter of an instrument broadcasts against it,
so a four-channel instrument is defined by giving the dispersion angle four values along that axis.
An instrument is a forward model and its transpose.
image() maps radiance to electrons,
and backproject() spreads the electrons in each pixel
back over every voxel of the scene that could have contributed to them.
Back-projection is not an inverse, but together the two operations are all that an iterative
inversion needs.
A linear instrument computes the sparse weights relating the scene and the sensor once,
and reuses them every time either operation is applied.
An inversion returns a result.
Calling an inverter on a set of images returns a result containing the reconstructed
solution,
a success flag and
message,
and the merit of every iteration,
so the convergence of the inversion can be inspected afterward.
Example#
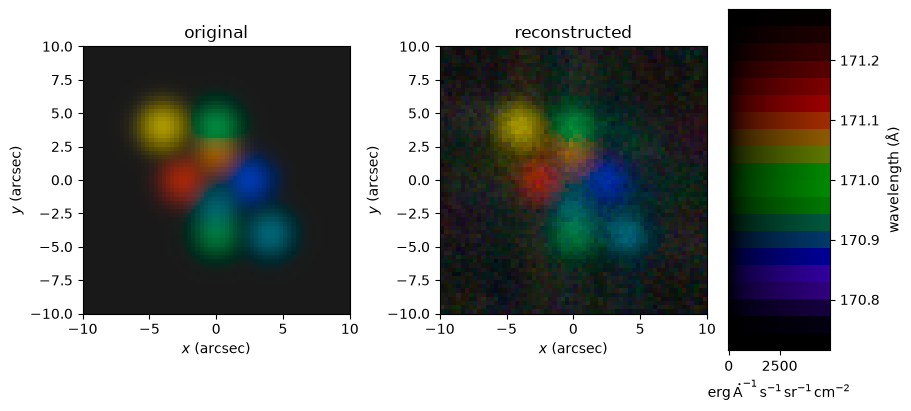
Simulate the images captured by an ideal four-channel CTIS observing a test scene, and reconstruct the scene from those images using MART. The hue of each pixel represents the Doppler shift of the spectral line, and the brightness represents its intensity.
import matplotlib.pyplot as plt
import astropy.units as u
import astropy.visualization
import named_arrays as na
import ctis

# Define the rest wavelength of the observed spectral line
wavelength_rest = 171 * u.AA

# Define a grid of Doppler velocities
velocity = na.linspace(-500, 500, axis="wavelength", num=21) * u.km / u.s

# Define the grid of wavelengths and sky positions
# on which to reconstruct the scene
coordinates_scene = na.DopplerPositionalVectorArray.from_velocity(
    velocity=velocity,
    wavelength_rest=wavelength_rest,
    position=na.Cartesian2dVectorLinearSpace(
        start=-10 * u.arcsec,
        stop=10 * u.arcsec,
        axis=na.Cartesian2dVectorArray("scene_x", "scene_y"),
        num=65,
    ),
)

# Define the vertices of the pixels on the sensor
coordinates_sensor = na.DopplerPositionalVectorArray.from_velocity(
    velocity=velocity,
    wavelength_rest=wavelength_rest,
    position=na.Cartesian2dVectorArray(
        x=na.arange(0, 129, axis="sensor_x") * u.pix,
        y=na.arange(0, 65, axis="sensor_y") * u.pix,
    ),
)

# Define a test scene of Gaussian blobs with different Doppler shifts
scene = ctis.scenes.gaussians(coordinates_scene)
scene = scene + scene.max() / 100

# Define an ideal CTIS with four channels,
# each dispersing the scene in a different direction
angle = na.linspace(0, 360, num=4, axis="channel", endpoint=False) * u.deg
instrument = ctis.instruments.IdealInstrument(
    area_effective=1 * u.cm**2,
    timedelta_exposure=20 * u.s,
    plate_scale=0.4 * u.arcsec / u.pix,
    dispersion=5.7 * u.mAA / u.pix,
    angle=angle + 5.64 * u.deg,
    wavelength_ref=wavelength_rest,
    position_ref=na.Cartesian2dVectorArray(64, 32) * u.pix,
    coordinates_scene=coordinates_scene,
    coordinates_sensor=coordinates_sensor,
    channel="dispersion angle = " + angle.to_string_array("%03d"),
    axis_channel="channel",
    axis_wavelength="wavelength",
    axis_scene_xy=("scene_x", "scene_y"),
    axis_sensor_xy=("sensor_x", "sensor_y"),
)

# Simulate the images captured by each channel,
# including photon shot noise
images = instrument.image(scene)

# Reconstruct the scene from the images using MART
inverter = ctis.inverters.MartInverter(instrument)
result = inverter(images)

# Plot the original and reconstructed scenes as false-color images
with astropy.visualization.quantity_support():
    fig, axs = plt.subplots(
        ncols=3,
        gridspec_kw=dict(width_ratios=[0.42, 0.42, 0.16]),
        constrained_layout=True,
        figsize=(9, 4),
    )
    for ax, s, title in zip(axs, [scene, result.solution], ["original", "reconstructed"]):
        colorbar = na.plt.rgbmesh(
            C=s,
            axis_wavelength="wavelength",
            ax=ax,
            vmin=0,
            vmax=scene.outputs.max(),
        )
        ax.set_aspect("equal")
        ax.set_title(title)
        ax.set_xlabel("$x$ (arcsec)")
        ax.set_ylabel("$y$ (arcsec)")
    na.plt.pcolormesh(
        C=colorbar,
        axis_rgb="wavelength",
        ax=axs[2],
    )
    axs[2].set_ylabel("wavelength (Å)")
    axs[2].yaxis.tick_right()
    axs[2].yaxis.set_label_position("right")
Discussions#
Explanations of the theory behind the inversion algorithms.
Tutorials#
Step-by-step examples of how to use this package.
Talks#
Slide decks for presenting this package.
Simulating and Inverting a CTIS Observation: a step-by-step walkthrough of Invert a Synthetic Scene with MART.
Citation#
If you use ctis in your research, please cite it.
The citation metadata is kept in
CITATION.cff,
which the “Cite this repository” button on the
GitHub page
can export as BibTeX or APA.
Every release of ctis is archived on Zenodo with its own DOI.
The concept DOI,
10.5281/zenodo.23086313,
always resolves to the latest version,
and the Zenodo page lists the DOI of every version.
Please include the version of ctis that you used,
which is given by importlib.metadata.version("ctis").
The BibTeX entry below uses the concept DOI.
To cite a specific version instead,
replace doi with the DOI of that version.
@software{ctis,
  author = {Smart, Roy T. and Parker, Jacob D. and Kankelborg, Charles C.},
  title = {ctis},
  version = {X.Y.Z},
  doi = {10.5281/zenodo.23086313},
  url = {https://github.com/sun-data/ctis},
}
API Reference#
A package for inverting imagery captured by a computed tomography imaging spectrograph. |
References#
Richard Gordon, Robert Bender, and Gabor T. Herman. Algebraic reconstruction techniques (art) for three-dimensional electron microscopy and x-ray photography. Journal of Theoretical Biology, 29(3):471–481, 1970. URL: https://www.sciencedirect.com/science/article/pii/0022519370901098, doi:https://doi.org/10.1016/0022-5193(70)90109-8.
M. Bertero and P. Boccacci. A simple method for the reduction of boundary effects in the Richardson-Lucy approach to image deconvolution. \aap , 437(1):369–374, July 2005. doi:10.1051/0004-6361:20052717.
J. Lewis Fox, Charles C. Kankelborg, and Roger J. Thomas. A Transition Region Explosive Event Observed in He II with the MOSES Sounding Rocket. \apj , 719(2):1132–1143, August 2010. doi:10.1088/0004-637X/719/2/1132.
L. B. Lucy. An iterative technique for the rectification of observed distributions. \aj , 79:745, June 1974. doi:10.1086/111605.
Jacob D. Parker, Roy T. Smart, Charles Kankelborg, Amy Winebarger, and Nelson Goldsworth. First Flight of the EUV Snapshot Imaging Spectrograph (ESIS). \apj , 938(2):116, October 2022. doi:10.3847/1538-4357/ac8eaa.
William Hadley Richardson. Bayesian-Based Iterative Method of Image Restoration. Journal of the Optical Society of America (1917-1983), 62(1):55, January 1972.